
产品定位
FOS-P300S-6DF 面向曲面机器人指尖,在正面、两侧与顶端形成共形触觉覆盖,适合多方向接触和复杂物体抓取。
标准交付
基础套件包含 5 只曲面触觉传感器、安装板、多通道 Hub、USB Type-C 连接线、Sensor App、协议与 Demo、机械 STEP 文件及 V0.5 规格书。

面向曲面机器人指尖与多方向接触,传感器端完成二维力解算,多通道 Hub 支持整手并行工作。Built for curved fingertips and multi-directional contact, with on-sensor 2D force processing and multi-channel Hub operation.
FOS-P300S-6DF 面向曲面机器人指尖,在正面、两侧与顶端形成共形触觉覆盖,适合多方向接触和复杂物体抓取。
基础套件包含 5 只曲面触觉传感器、安装板、多通道 Hub、USB Type-C 连接线、Sensor App、协议与 Demo、机械 STEP 文件及 V0.5 规格书。
FOS-P300S-6DF provides conformal tactile coverage across the front, sides and tip of a curved robotic fingertip, supporting multi-directional contact and grasping of complex objects.
The base kit includes five curved tactile sensors, a mounting plate, a multi-channel Hub, a USB Type-C cable, Fulai Sensor App, protocols and demos, mechanical STEP files, and V0.5 specifications.
| 触觉点数量Taxel count | 2828 |
|---|---|
| 有效感知区域Active sensing area | 26 × 32 mm26 × 32 mm |
| 最小可检测法向力Minimum detectable normal force | 0.2 N0.2 N |
| 法向力量程Normal-force range | 0.2-20 N0.2-20 N |
| 力分辨率Force resolution | 0.1 N0.1 N |
| 空间分辨率Spatial resolution | <1 mm<1 mm |
| 法向力精度Normal-force accuracy | 5-10% FS5-10% FS |
| 表面覆盖Surface coverage | 正面、两侧与顶端Front, sides and tip |
| 采样频率Sampling rate | 100 Hz / 通道100 Hz per channel |
| Hub 通道数Hub capacity | 最多 5 路传感器Up to 5 sensor channels |
| 通信接口Communication | 传感器 UART / 主机 USB Type-C,921,600 baudSensor UART / host USB Type-C, 921,600 baud |
| 供电与功耗Power | 3.3-5 V DC,<10 mA / 传感器,<50 mW / 传感器3.3-5 V DC, <10 mA per sensor, <50 mW per sensor |
| 模块尺寸Module dimensions | 20 × 25.41 × 14.62 mm20 × 25.41 × 14.62 mm |
| 线缆长度Cable length | 250 mm250 mm |
| 工作温度Operating temperature | -20 至 40 °C-20 to 40 °C |
传感器端输出法向力并提供合剪切力估算,剪切力标定量程与精度以实际表征报告为准。The sensor outputs normal force and an estimated resultant shear force. Calibrated shear range and accuracy are subject to the actual characterization report.
| 形态Form | 型号Model | 适用场景Application |
|---|---|---|
| 曲面指尖Curved fingertip | FOS-P300S-6DFFOS-P300S-6DF | 多方向接触、复杂物体抓取与整手触觉可视化Multi-directional contact, complex-object grasping and whole-hand tactile visualization |
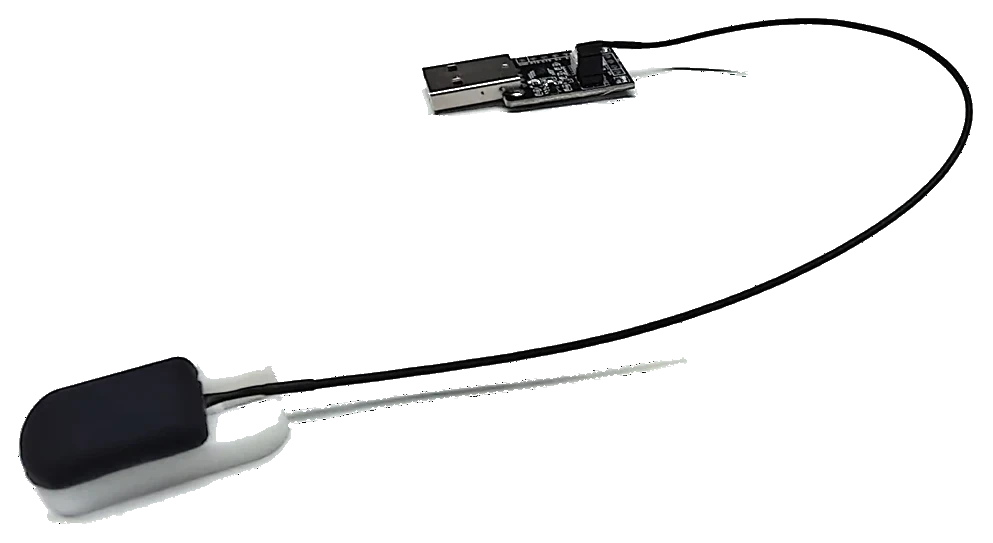
96 个触觉点的平面指尖触觉传感器,支持 100 Hz 法向力反馈与主机端剪切力估算。A 96-taxel flat-fingertip tactile sensor with 100 Hz normal-force feedback and host-side shear estimation.
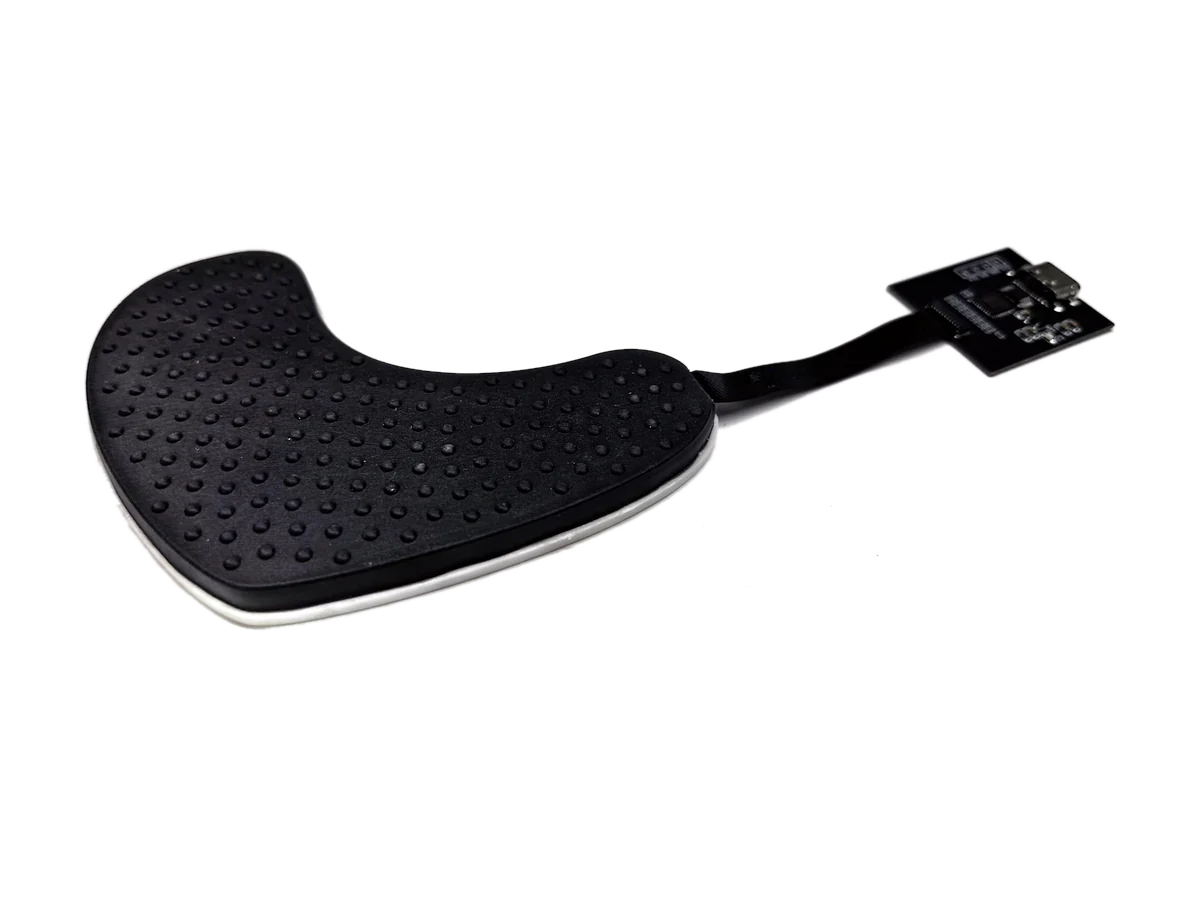
53 个触觉点覆盖 70 × 80 mm 手掌区域,适合支撑、包络抓取和大面积接触定位。A 53-taxel palm tactile sensor covering 70 × 80 mm for support, enveloping grasps and large-area contact localization.
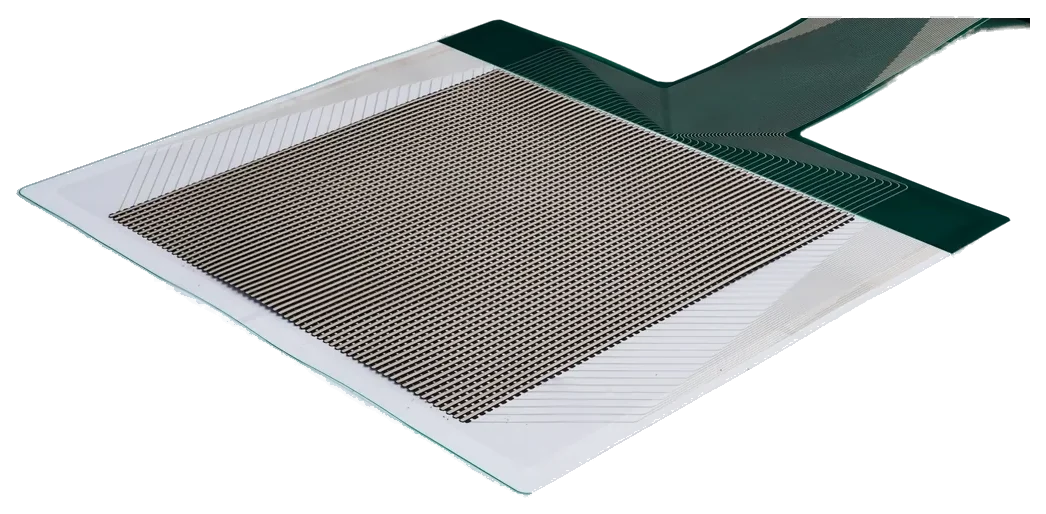
按应用场景选配尺寸、形态、量程和感测区域,已确认 4 个型号与对应工艺。Application-specific sensor selection by size, shape, range and sensing area, with four model-to-process mappings confirmed.